
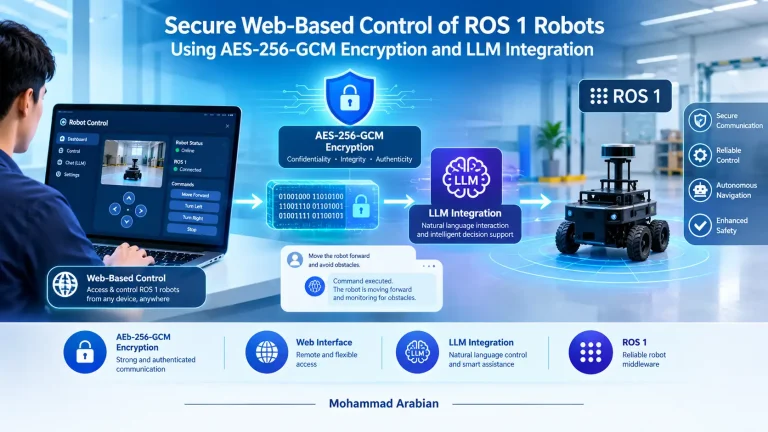
Secure Web-Based Control of ROS 1 Robots Using AES-256-GCM Encryption and LLM Integration
Authors: Mohammad Arabian, Ali Godarzvand Chegini
Abstract
This paper presents the design and implementation of a secure web-based control system for a Robot Operating System (ROS) robot. The proposed framework enables real-time bidirectional communication between a ROS environment and a PHP-based web server, allowing users to control and monitor the robot remotely through any standard web browser. To ensure confidentiality, integrity, and authenticity of transmitted commands and sensor data, the system employs AES-256-GCM symmetric encryption and message authentication mechanisms. A lightweight communication protocol was developed to minimize latency while maintaining cryptographic strength. Experimental results demonstrate reliable control with negligible delay and verified data integrity even under unstable network conditions. The proposed solution provides an accessible and secure approach to remote robot management suitable for educational, research, and industrial applications.